
"Right Arm" — Computer Vision Robotic Arm
A robotic arm you control with your hand. No controller, no buttons — the camera watches, and the arm follows.
- Built a real-time vision control system with OpenCV and MediaPipe, tracking hand landmarks and mapping 2D image coordinates through inverse kinematics into arm position.
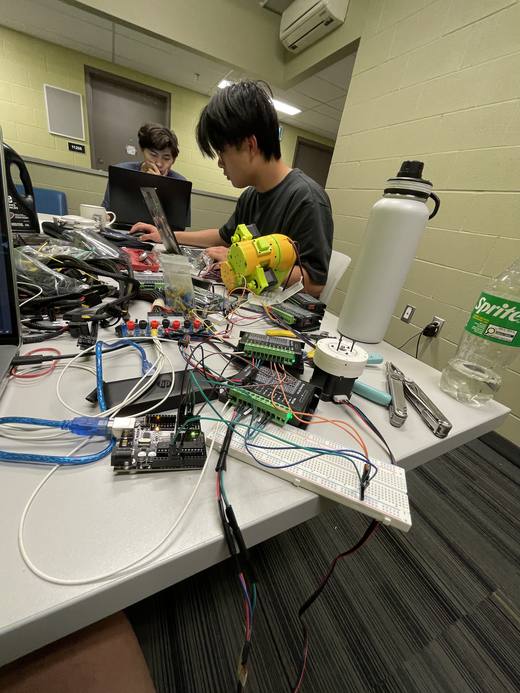
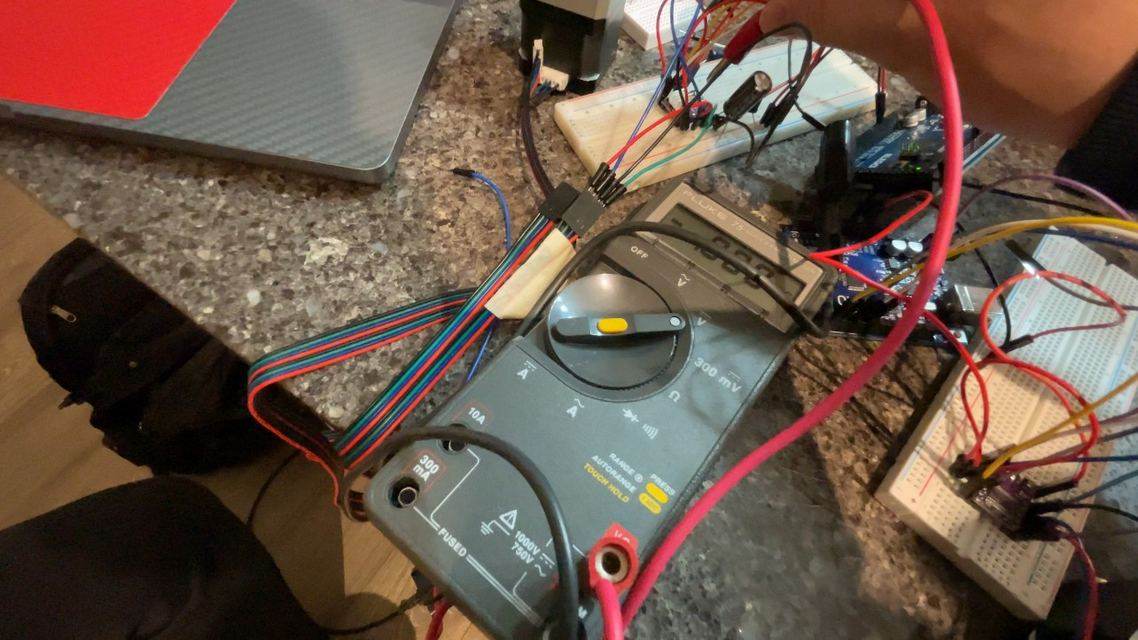
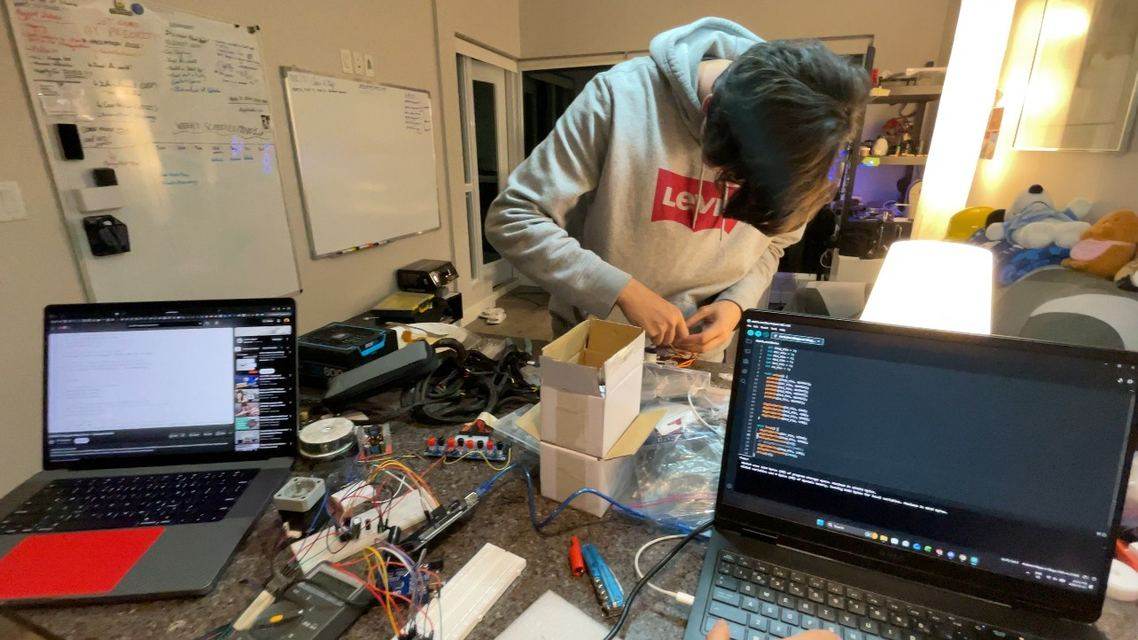
- Integrated embedded systems — Arduino, motor drivers, sensors — to drive actuators and process feedback, prototyping multiple configurations to tune accuracy and stability.
- Debugged cross-domain failures spanning hardware, firmware, and software in a team dev environment.
OpenCV · MediaPipe · Python · Arduino · Inverse kinematics